Journals and Conference Papers
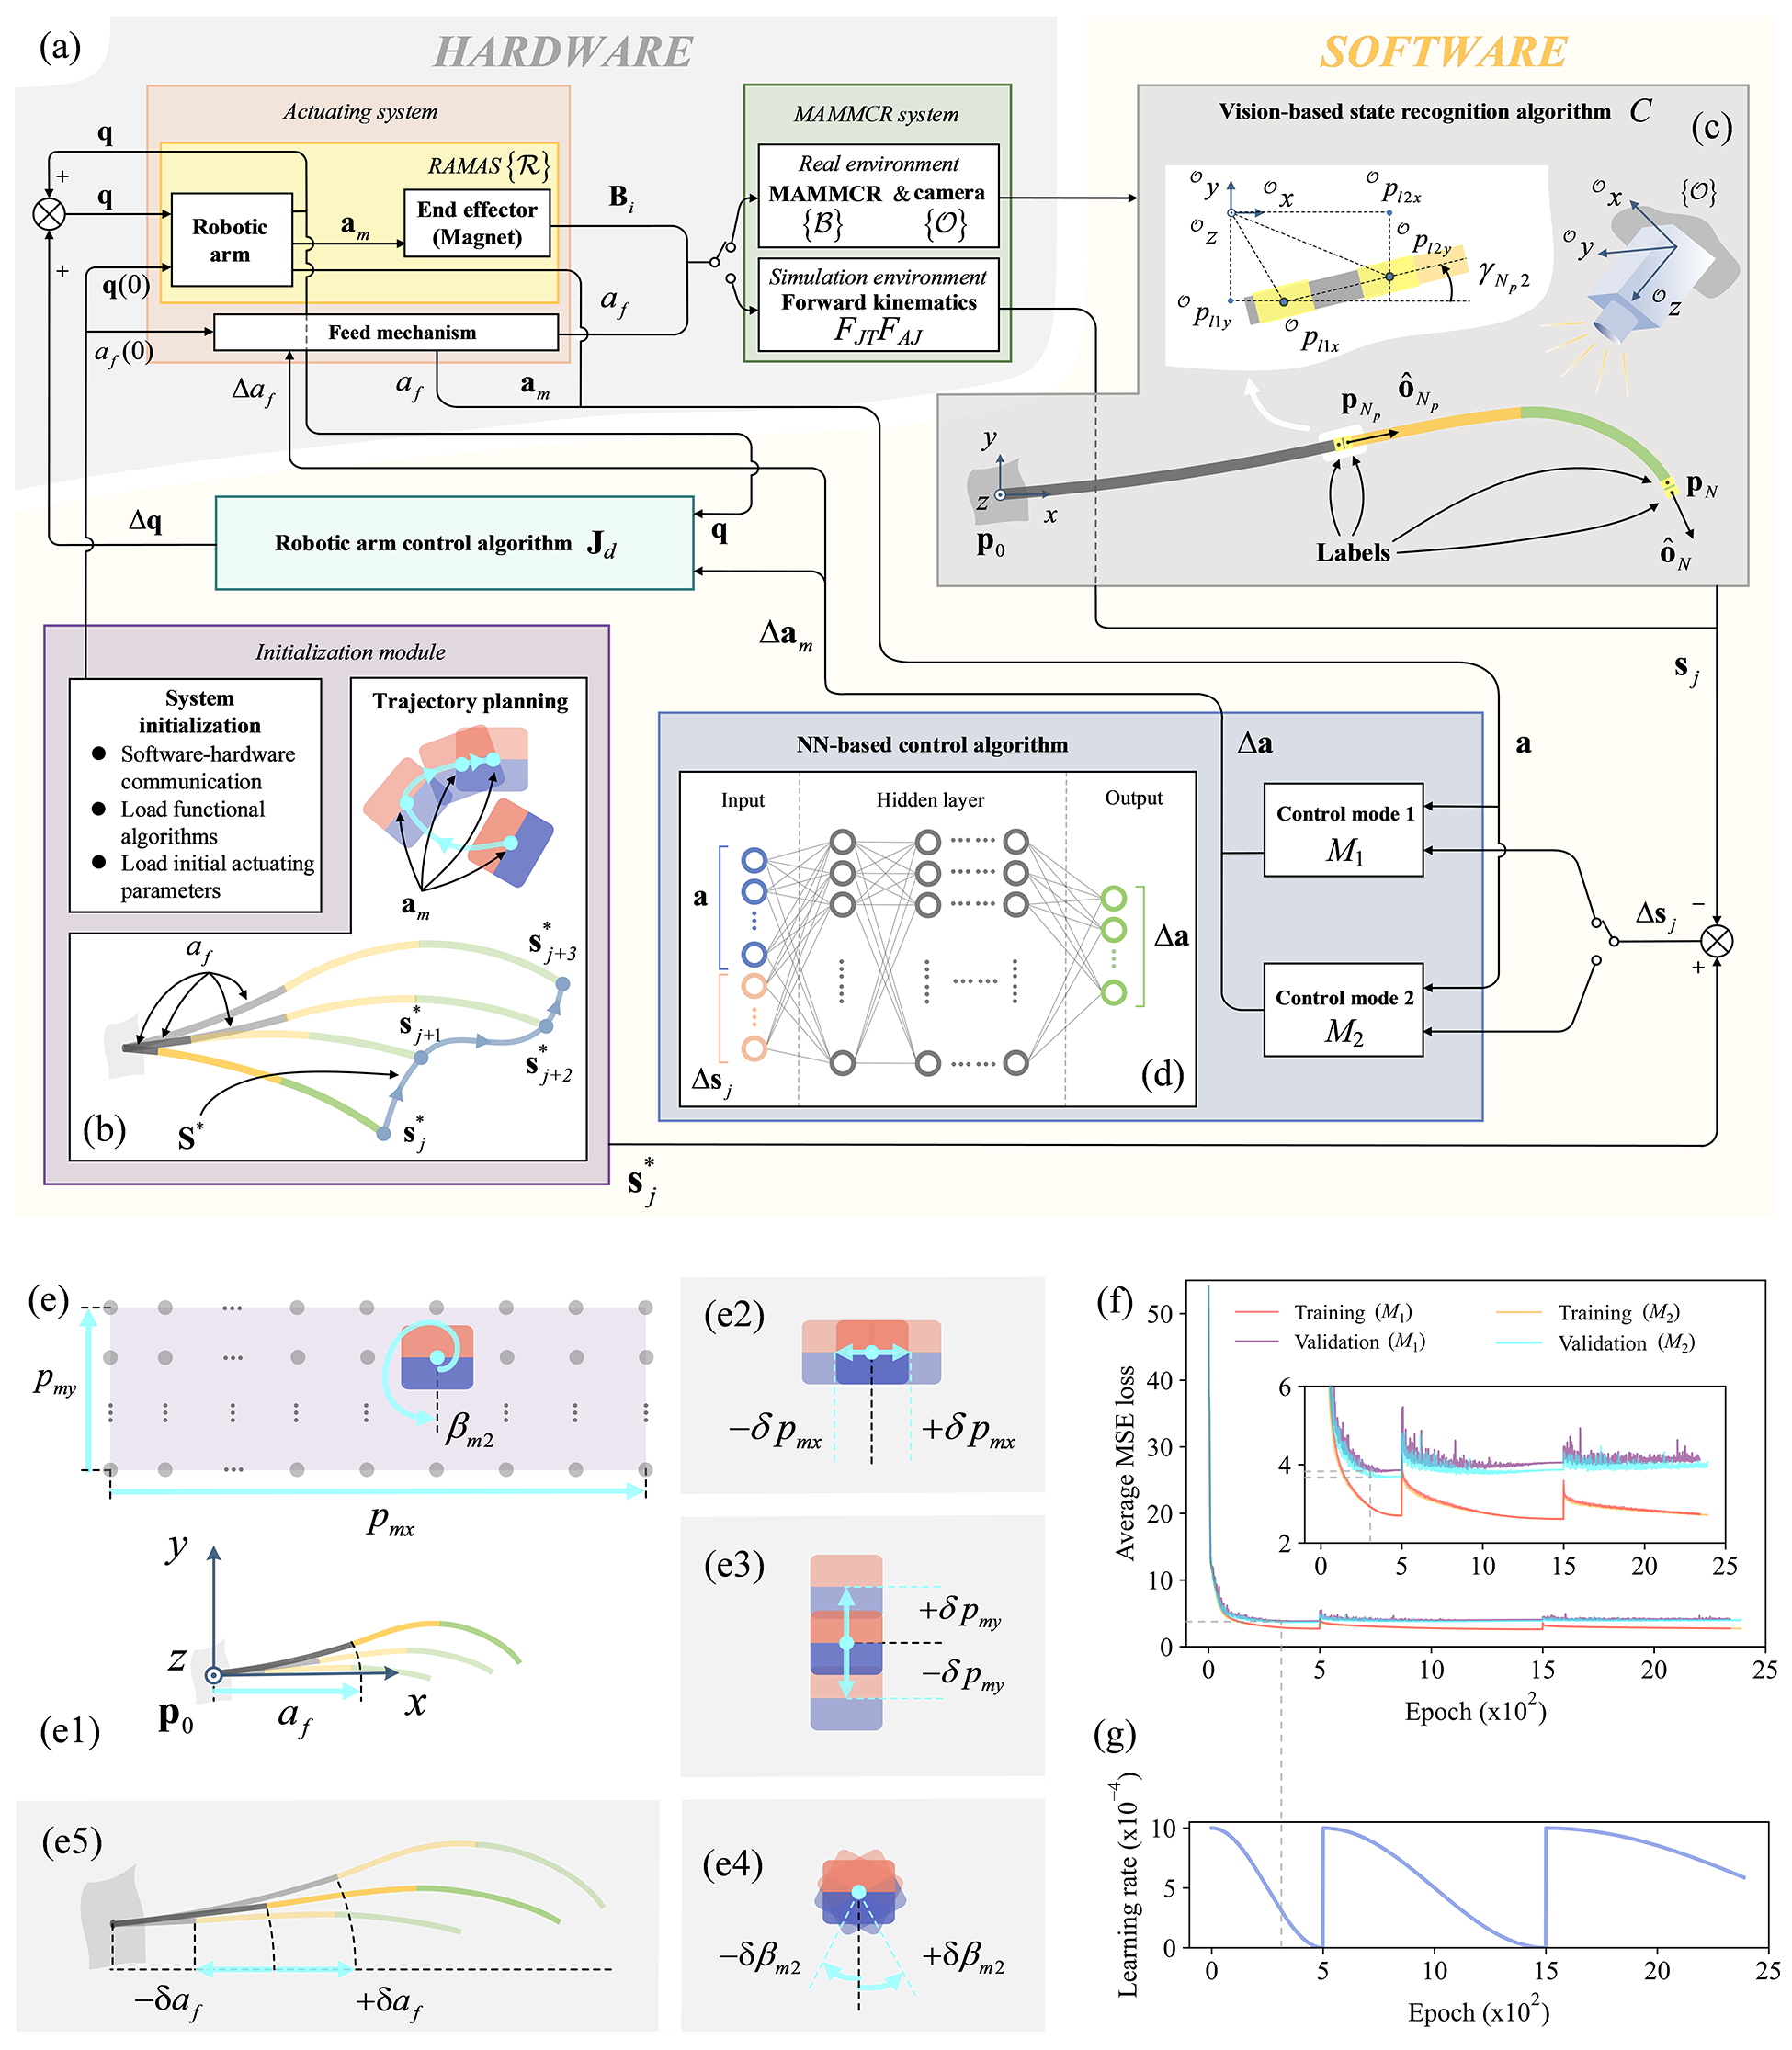
Y. Cao, M. Cai, B. Sun, Z. Qi, J. Xue, Y. Jiang, B. Hao, J. Zhu, X. Liu, C. Yang, L. Zhang*, Magnetic Continuum Robot with Modular Axial Magnetization: Design, Modeling, Optimization, and Control, IEEE Transactions on Robotics, 2025, vol. 41, pp. 1513-1532, DOI: 10.1109/TRO.2025.3526077. LINK (🔥Highlighted in 机器人大讲堂)
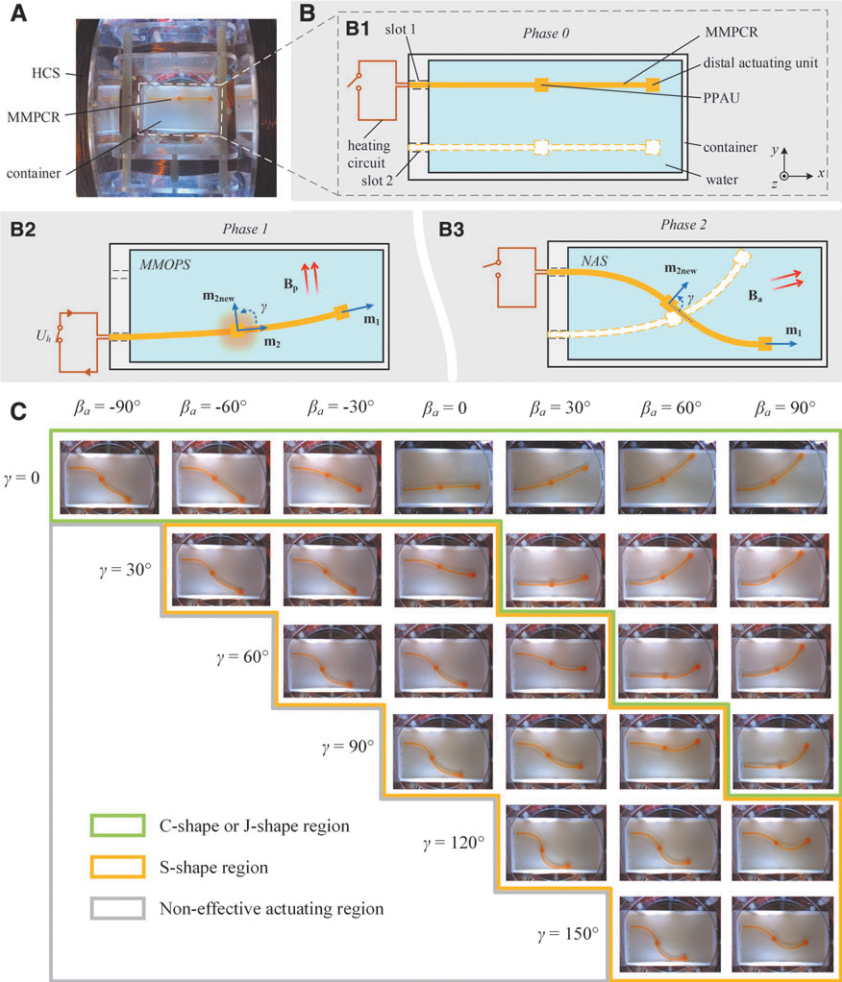
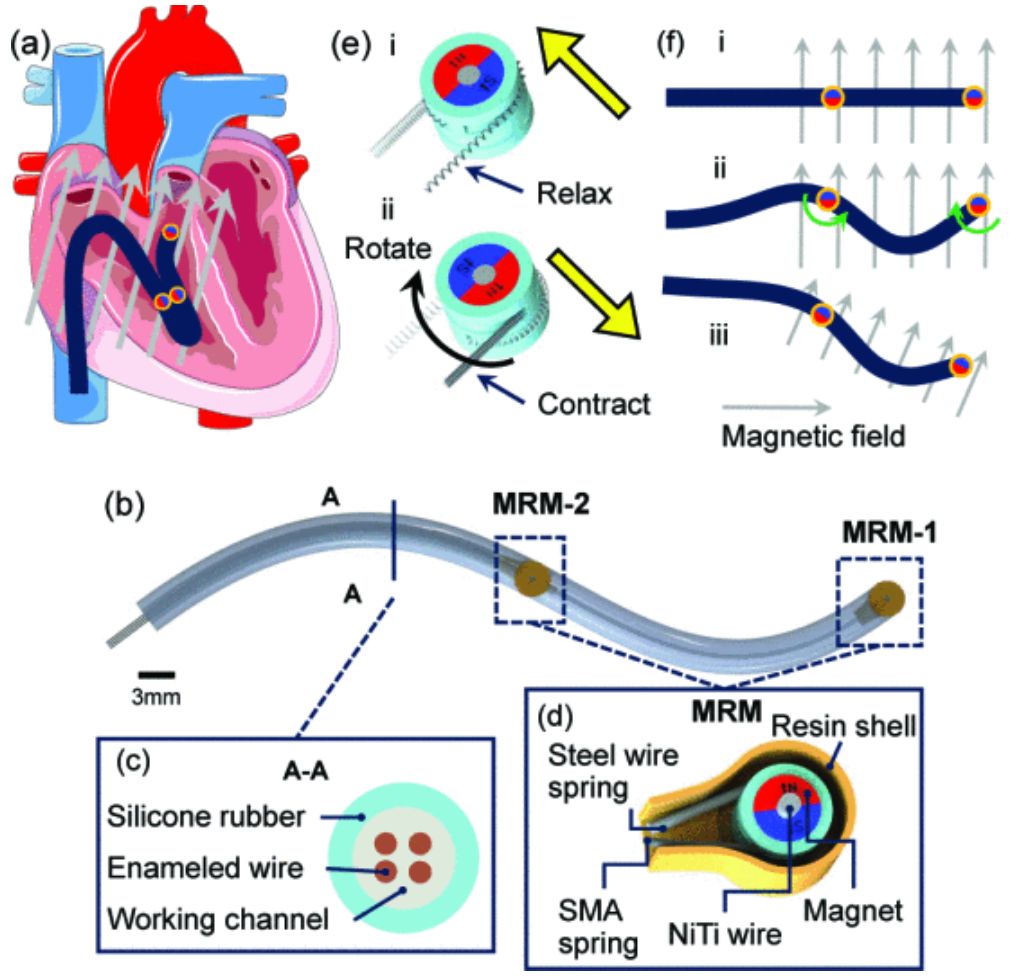
Y. Cao, Z. Yang, B. Hao, X. Wang, M. Cai, Z. Qi, B. Sun, Q. Wang, L. Zhang*, Magnetic continuum robot with intraoperative magnetic moment programming, Soft Robotics, 2023, vol. 10(6), pp. 1209-1223, DOI: 10.1089/soro.2022.0202. LINK
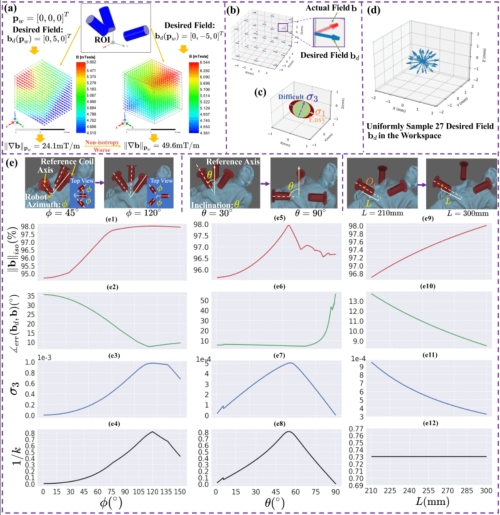
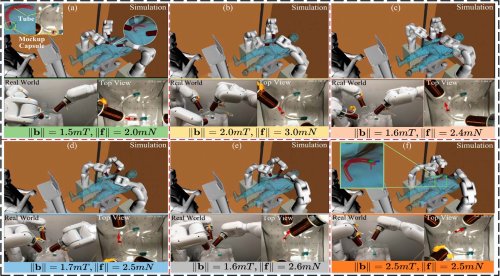
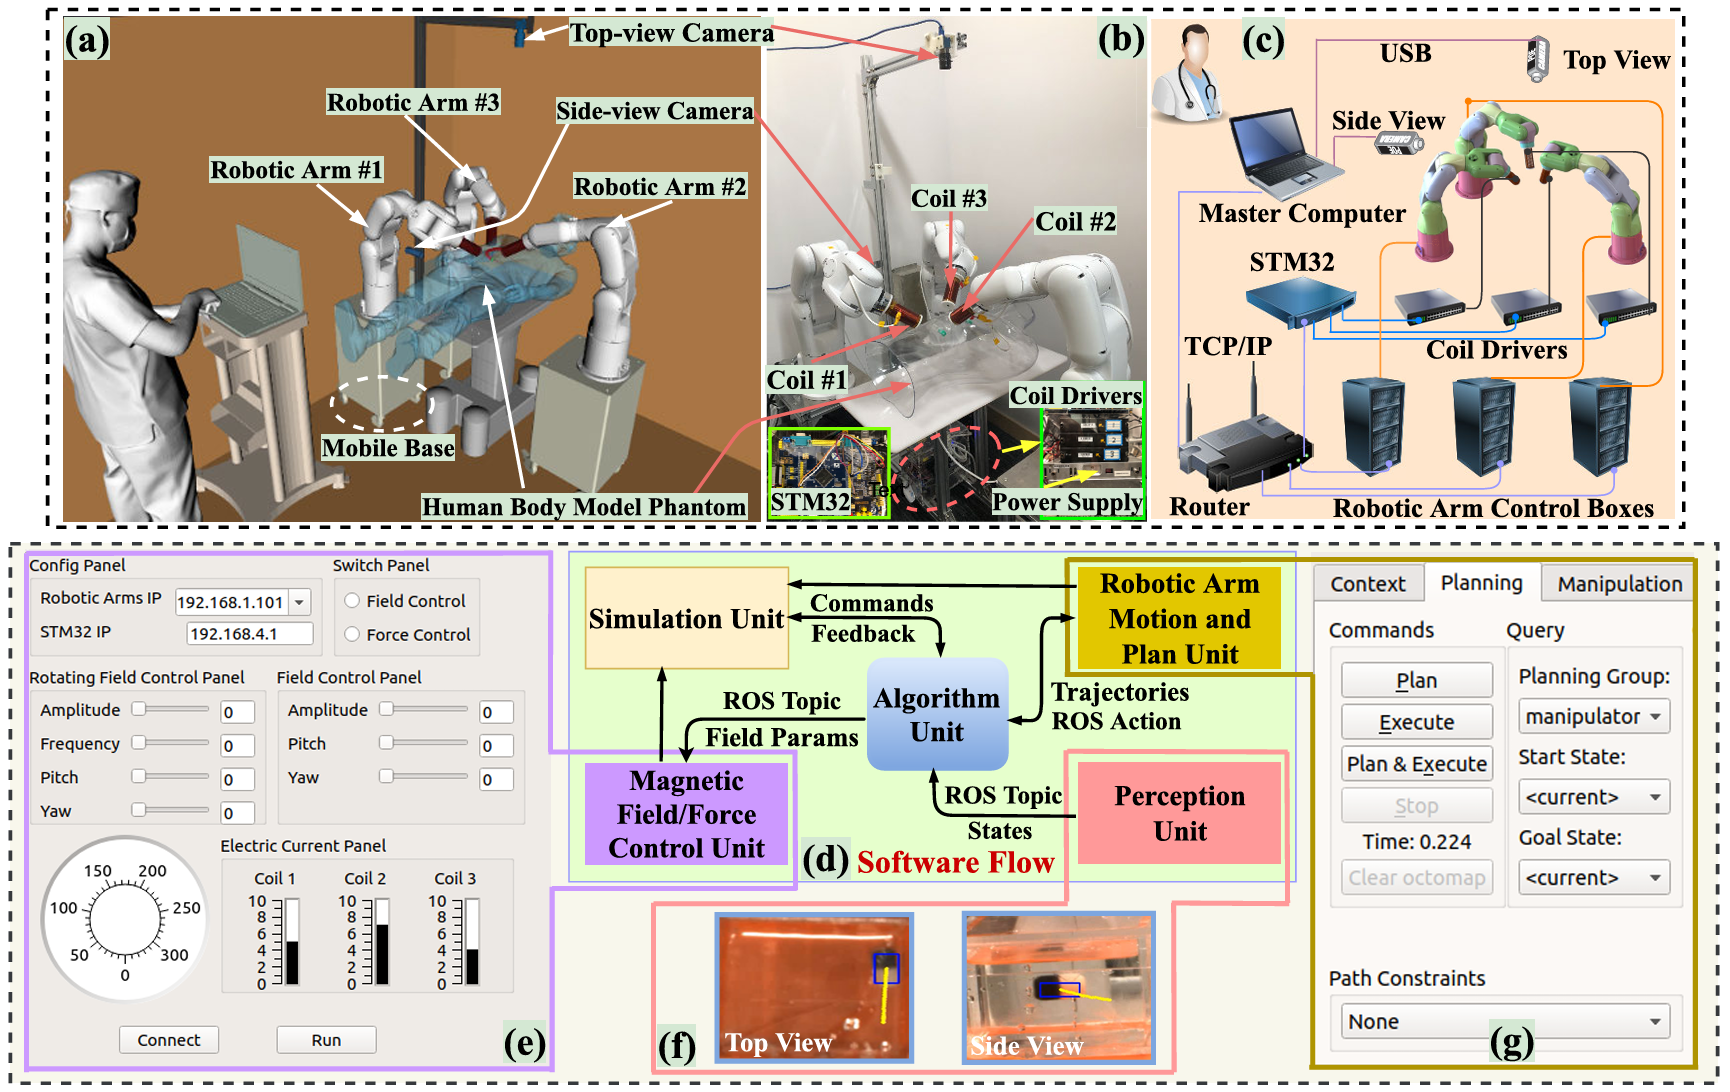
M. Cai, Z. Qi, Y. Cao, X. Liu, X. Wu, T. Xu*, L. Zhang*, Performance-Guided Rotating Magnetic Field Control in Large Workspaces With Reconfigurable Electromagnetic Actuation System, IEEE Transactions on Robotics, 2024, vol. 40, pp. 4117-4131, DOI: 10.1109/TRO.2024.3453768. LINK (🔥Highlighted in 机器人大讲堂)
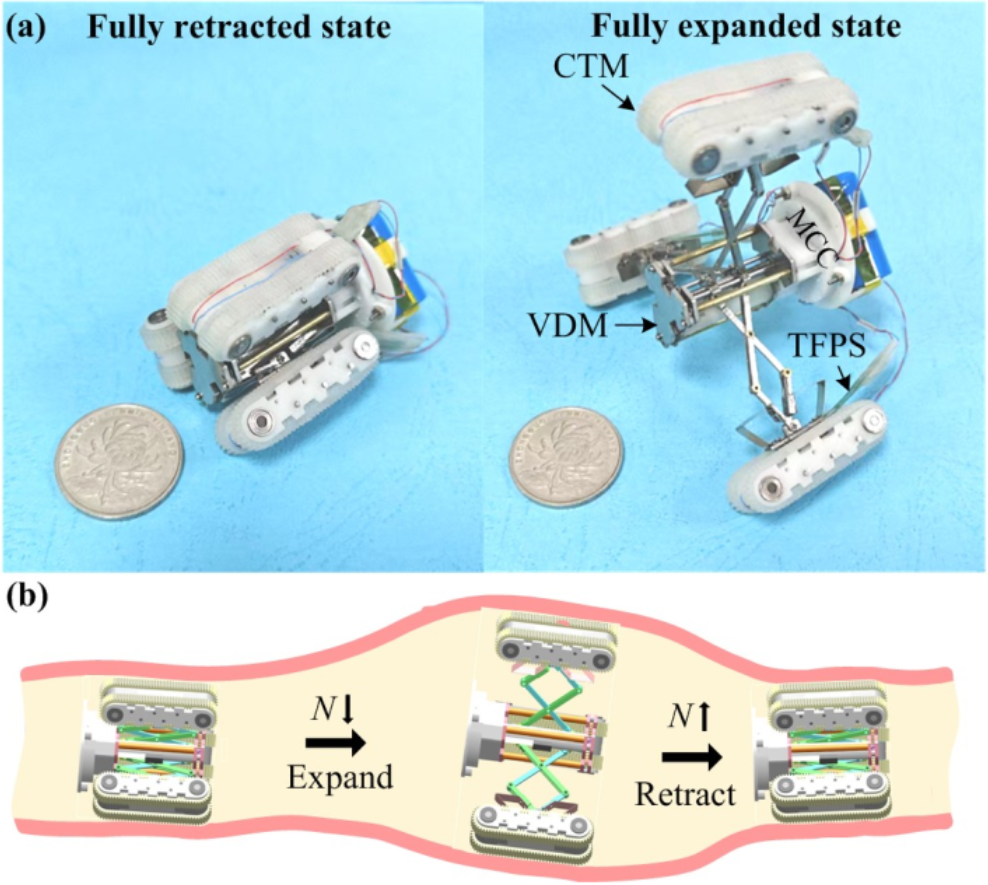
J. Gao*, Z. Hu, J. Zhang, Y. Cao, K. Zhang, G. Yan, H. Dong, Q. Tan*, L. Zhang*, A Caterpillar-Type Miniature Robot for Adaptive Locomotion and Exploration of Tiny Rigid/Soft Pipes, IEEE Transactions on Robotics, 2026, vol. 42, pp. 2345-2359, DOI: 10.1109/TRO.2026.3697140. LINK (🔥Highlighted in 机器人大讲堂)
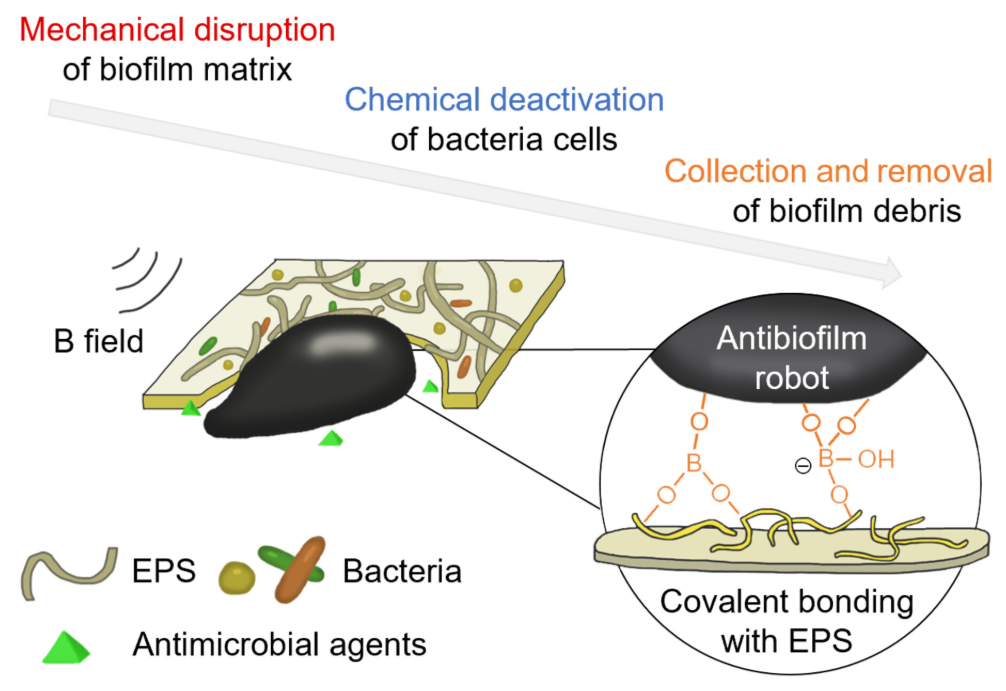
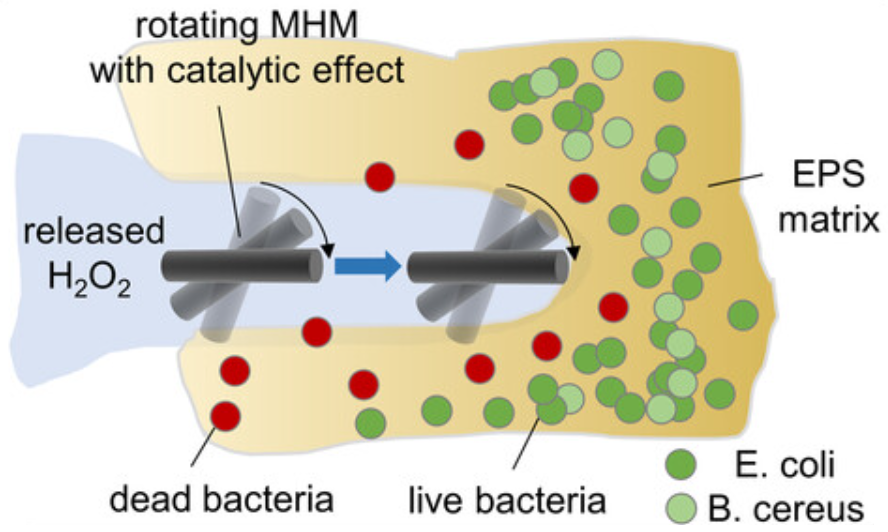
B. Sun, J. Guo, B. Hao, Y. Cao, T. K. F. Chan, M. Sun*, J. J. Y. Sung*, L. Zhang*, Liquid-bodied antibiofilm robot with switchable viscoelastic response for biofilm eradication on complex surface topographies, Science Advances, 2025, vol. 11: eadt8213, DOI: 10.1126/sciadv.adt8213. LINK (🔥Highlighted in 高分子科学前沿)
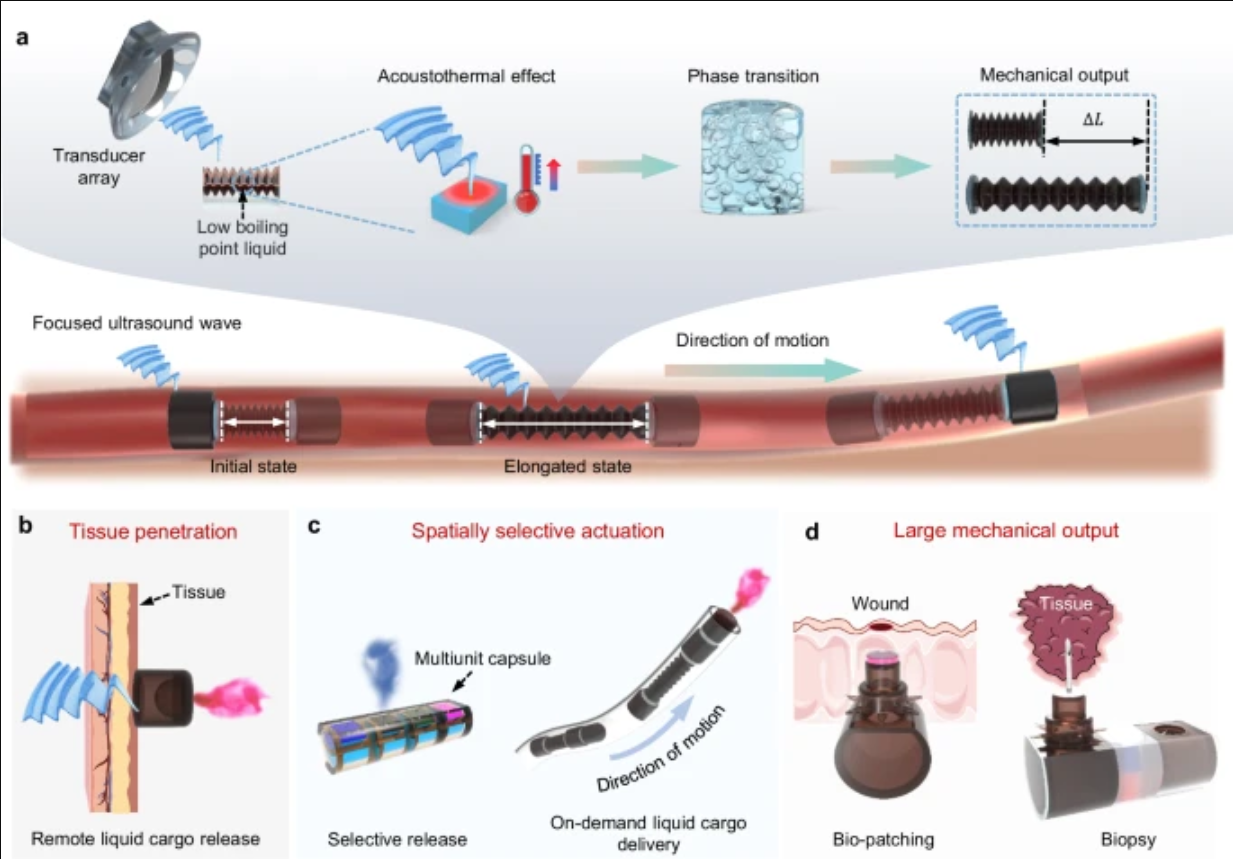
B. Hao, X. Wang, Y. Dong*, M. Sun, C. Xin, H. Yang, Y. Cao, J. Zhu, X. Liu, C. Zhang, L. Su, B. Li*, L. Zhang*, Focused ultrasound enables selective actuation and Newton-level force output of untethered soft robots, Nature Communications, 2024, vol. 15(1): 5197, DOI: 10.1038/s41467-024-49148-6. LINK (🔥Highlighted in 高分子科学前沿)
M. Cai, Z. Qi, Y. Cao, X. Wu, T. Xu*, L. Zhang*, Magnetic Field-Priority Force Control for Automated Manipulation in Large Workspaces With Reconfigurable Electromagnetic Actuation System, IEEE Transactions on Industrial Electronics, 2024, vol. 72(2), pp. 1732-1742, DOI: 10.1109/TIE.2024.3426055. LINK
M. Cai, Z. Qi, Y. Cao, X. Wu, T. Xu*, L. Zhang*, Development of reconfigurable electromagnetic actuation system with large workspaces: Design, optimization, and validation, IEEE Transactions on Automation Science and Engineering, 2024, vol. 22, pp. 5982-5993, DOI: 10.1109/TASE.2024.3435035. LINK
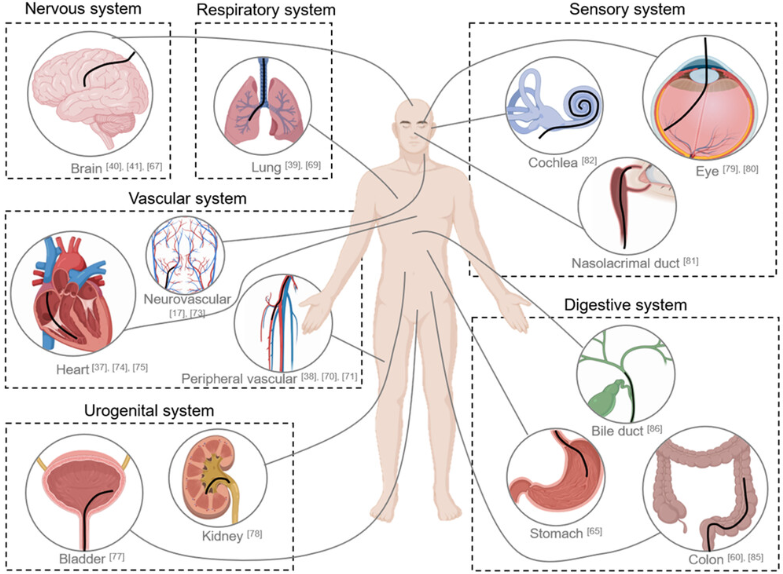
Z. Yang, H. Yang, Y. Cao, Y. Cui, L. Zhang*. Magnetically actuated continuum medical robots: a review, Advanced Intelligent Systems, 2023, vol. 5(6): 2200416, DOI: 10.1002/aisy.202200416. LINK (🔥TOP 10 Most-Cited Article in 2023)
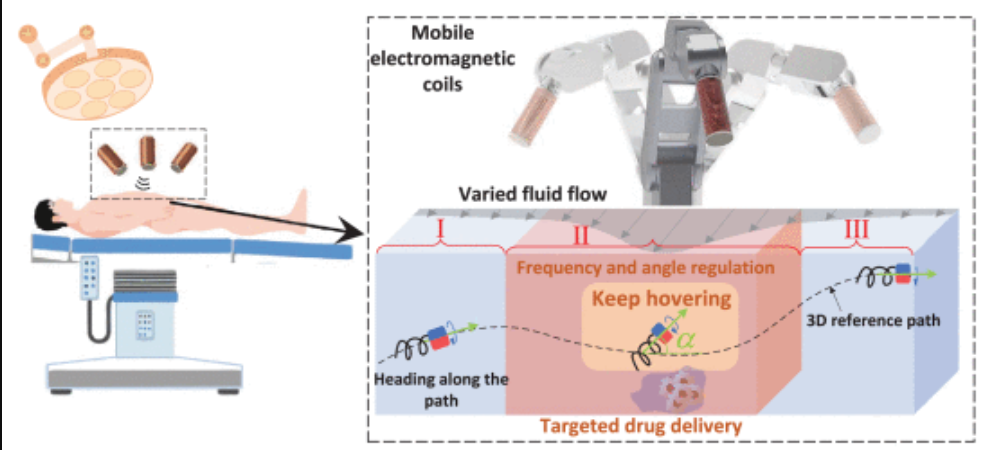
Z. Qi, M. Cai, B. Hao, Y. Cao, L. Su, X. Liu, K. F. Chan, C. Yang, L. Zhang*, Robust 3-D Path Following Control Framework for Magnetic Helical Millirobots Subject to Fluid Flow and Input Saturation, IEEE Transactions on Cybernetics, 2024, vol. 54(12), pp: 7629-7641, DOI: 10.1109/TCYB.2024.3439708. LINK
J. Xue, M. Zhang, X. Liu, J. Zhu, Y. Cao, L. Zhang*, A Magnetic Continuum Robot with In-situ Magnetic Reprogramming Capability, 2024 IEEE International Conference on Robotics and Automation (ICRA), 2024, pp: 5891-5897, DOI: 10.1109/ICRA57147.2024.10611450. LINK
B. Sun, M. Sun*, Z. Zhang, Y. Jiang, B. Hao, X. Wang, Y. Cao, T. K. F. Chan*, L. Zhang*, Magnetic hydrogel micromachines with active release of antibacterial agent for biofilm eradication, Advanced Intelligent Systems, 2023, vol. 6(2): 2300092, DOI: 10.1002/aisy.202300092. LINK (🔥Highlighted in Advanced Science News)
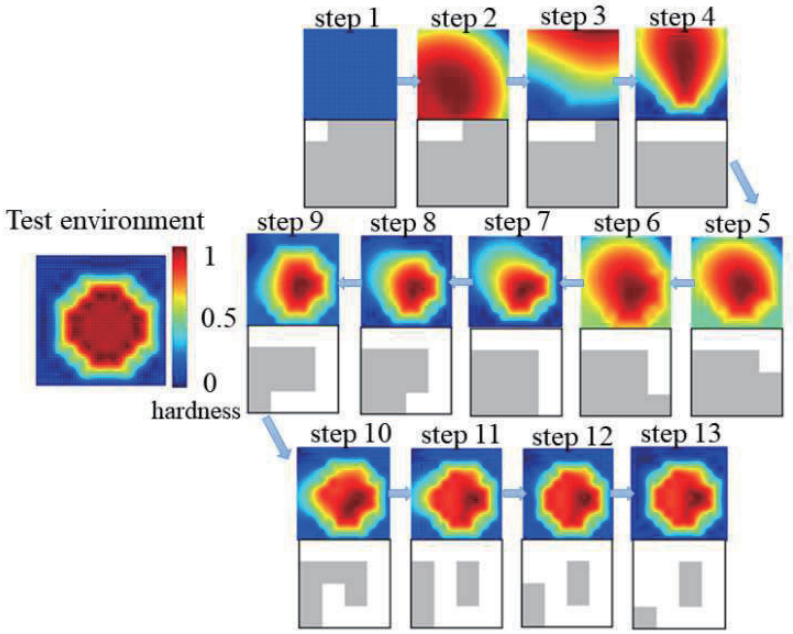
F. Ju*, H. Ye, D. Bai, Y. Zhang, C. Zhu, Y. Cao, W. Yue, Autonomous tumor palpation and resection path planning using tactile array sensor and deep reinforcement learning for surgical robot, 2022 IEEE International Conference on Robotics and Biomimetics (ROBIO), 2022, pp. 871-876, DOI: 10.1109/ROBIO55434.2022.10012022. LINK
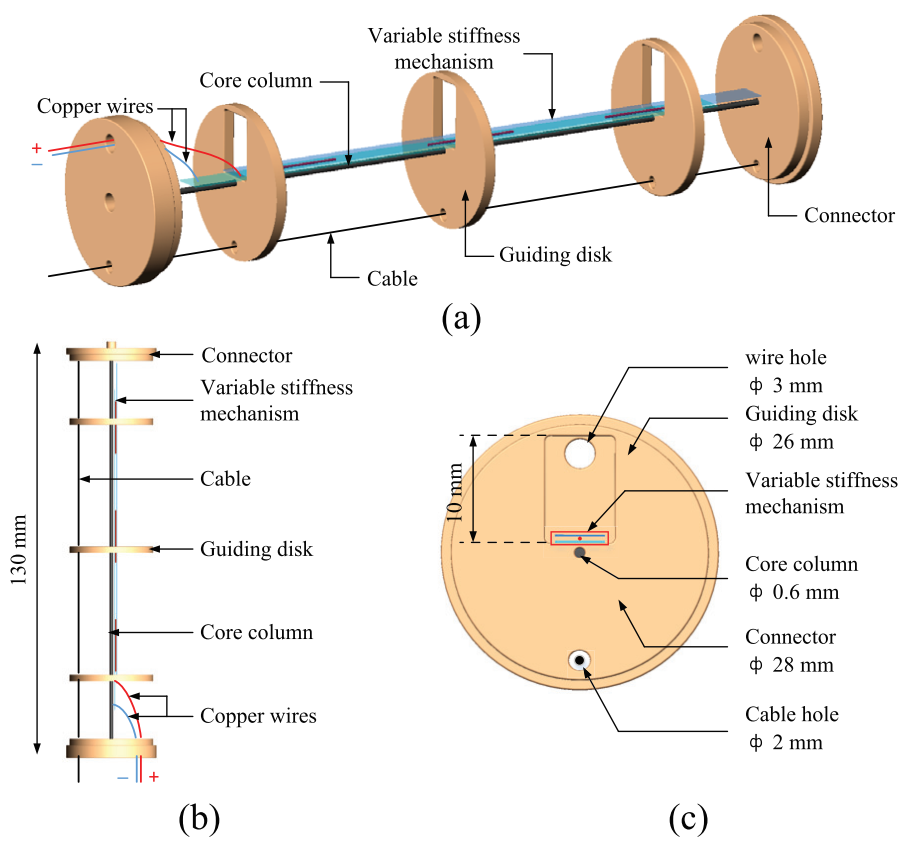
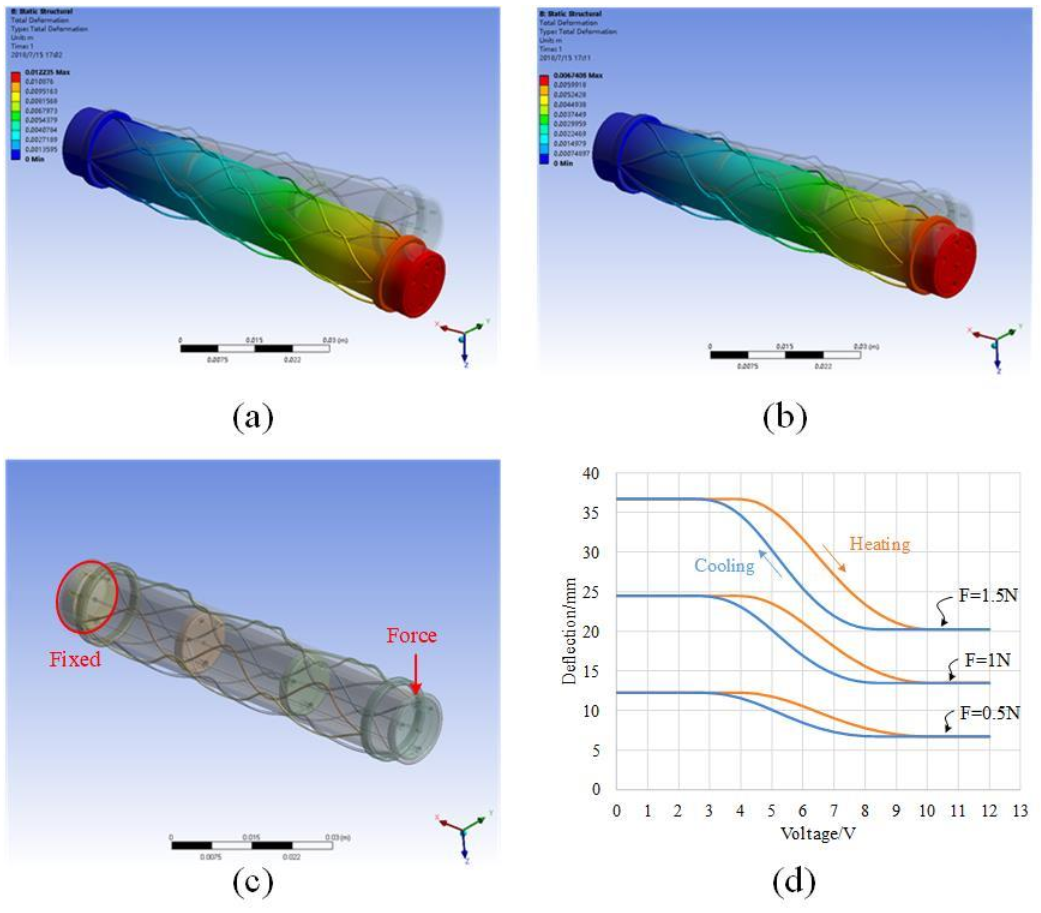
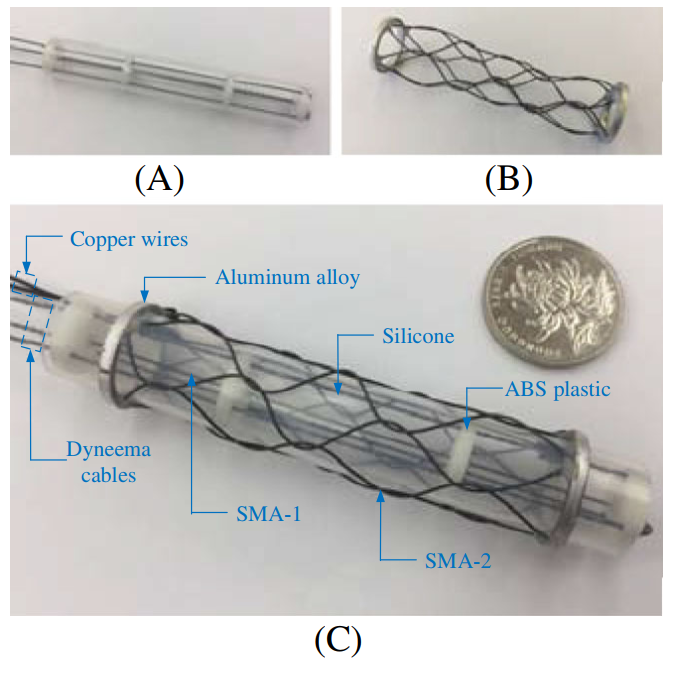
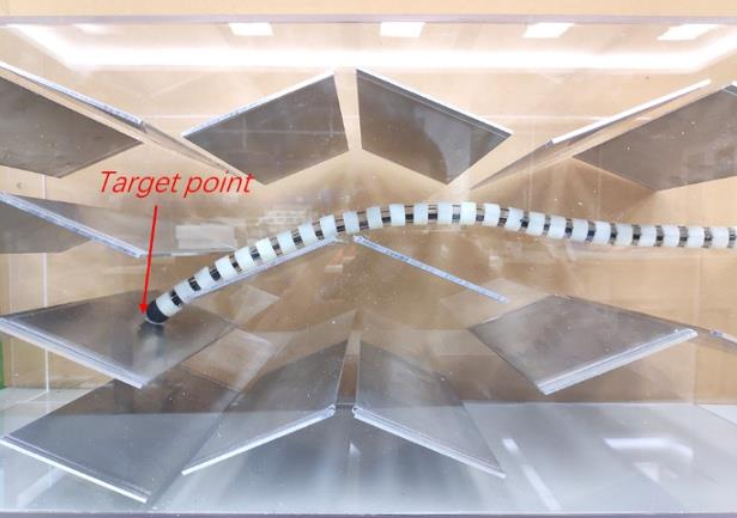
Y. Cao, F. Ju, L. Zhang, D. Bai, F. Qi, B. Chen*, A novel variable-stiffness flexible manipulator actuated by shape memory alloy for minimally invasive surgery, Proceedings of the Institution of Mechanical Engineers, Part H: Journal of Engineering in Medicine, 2018, vol. 232(11), pp. 1098-1110, DOI: 10.1177/0954411918802922. LINK
Y. Cao*, F. Ju, B. Chen, A novel variable stiffness continuum manipulator with a SMA-based sheath for minimally invasive surgery, 2018 International Academic Conference for Graduates, NUAA (IACGN, 2018), Oct. 18-19, 2018, Nanjing, China, vol. 5, pp. 26-31. (Best Paper Award) LINK
S. Jiang, B. Chen*, F. Qi, Y. Cao, F. Ju, D. Bai, Y. Wang, A variable-stiffness continuum manipulators by an SMA-based sheath in minimally invasive surgery, The International Journal of Medical Robotics and Computer Assisted Surgery, 2020, vol. 16(2), pp. 1-11, DOI: 10.1002/rcs.2081. LINK
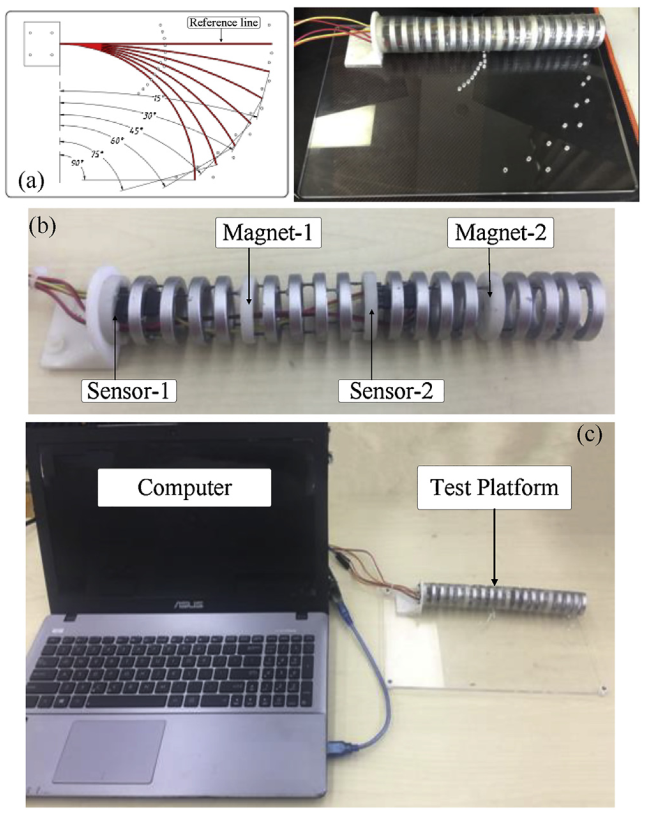
H. Guo, F. Ju, Y. Cao, F. Qi, D. Bai, Y. Wang, B. Chen*, Continuum robot shape estimation using permanent magnets and magnetic sensors, Sensors and Actuators A: Physical, 2019, vol. 285, pp. 519-530, DOI: 10.1016/j.sna.2018.11.030. LINK
Y. Wang, F. Ju, Y. Cao, Y. Yun, Y. Wang, D. Bai, B. Chen*, An aero-engine inspection continuum robot with tactile sensor based on EIT for exploration and navigation in unknown environment, IEEE 2019 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), Jul. 8-12, 2019, Hong Kong, China, pp. 1157–1162, DOI:10.1109/aim.2019.8868485. LINK
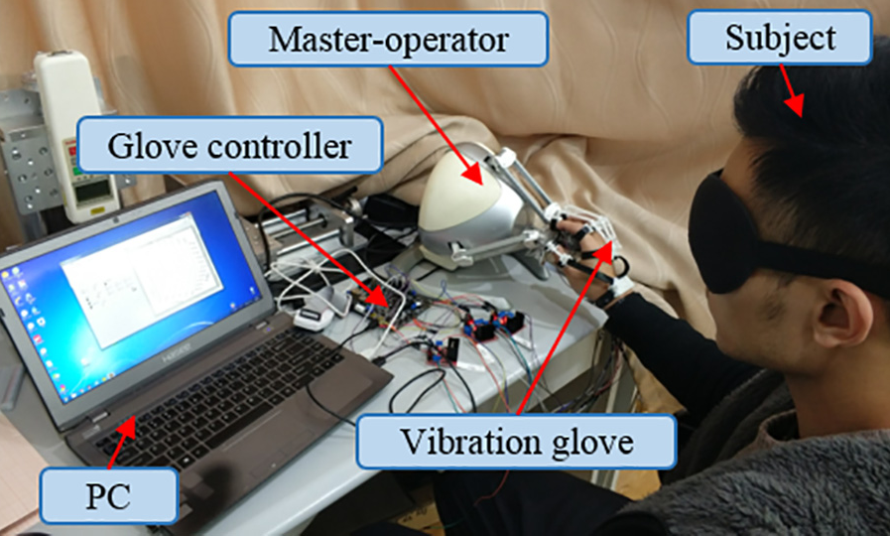
D. Bai, F. J, F. Qi, Y. Cao, Y. Wang, B. Chen*, A wearable vibrotactile system for distributed guidance in teleoperation and virtual environments, Proceedings of the Institution of Mechanical Engineers, Part H: Journal of Engineering in Medicine, 2019, vol. 233(2), pp. 1-10, DOI: 10.1177/0954411918821387. LINK
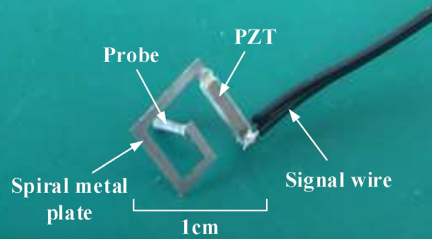
L. Zhang, F. Ju, Y. Cao, Y. Wang, B. Chen*, A tactile sensor for measuring hardness of soft tissue with applications to minimally invasive surgery, Sensors and Actuators A: Physical, 2017, vol. 266, pp. 197-204, DOI: 10.1016/j.sna.2017.09.012. LINK
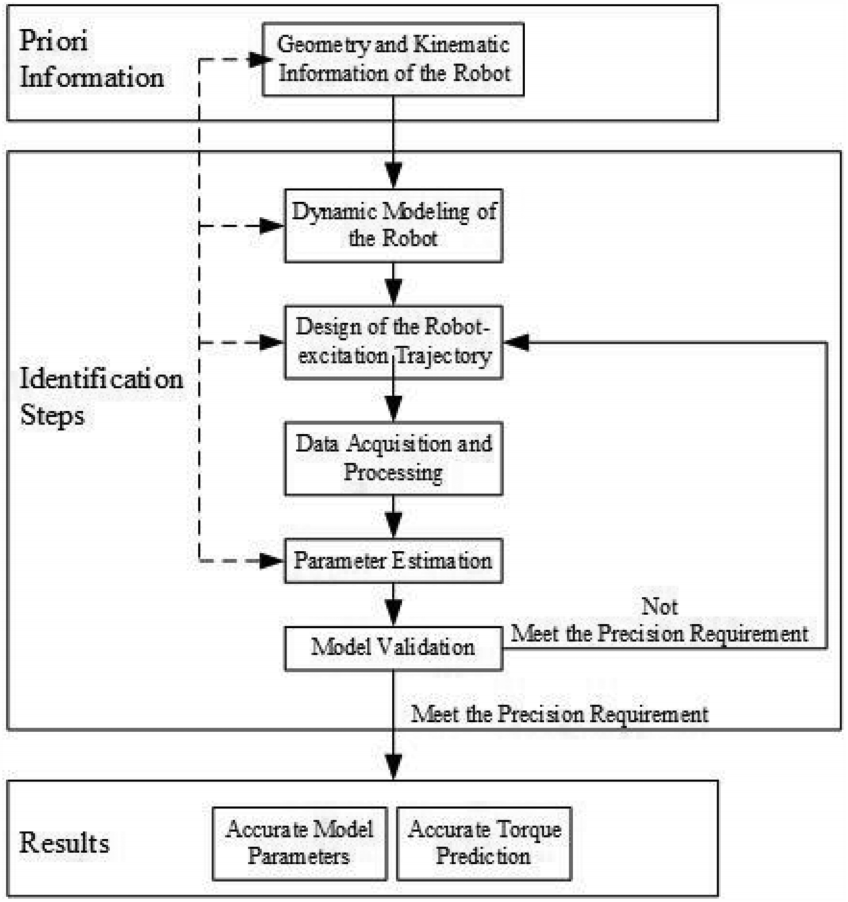
S. Jiang, M. Jiang, Y. Cao, D. Hua, H. Wu, Y. Ding, B. Chen*, A typical dynamic parameter identification method of 6-degree-offreedom industrial robot, Proceedings of the Institution of Mechanical Engineers, Part I: Journal of Systems and Control Engineering, 2017, vol. 231(9), pp. 740-752, DOI: 10.1177/0959651817726477. LINK
2022-Now
2017-2020